How to Choose an Excavator for Demolition Based on Reach, Attachment Weight, and Jobsite Risk
Start with the demolition envelope, not the base machine size
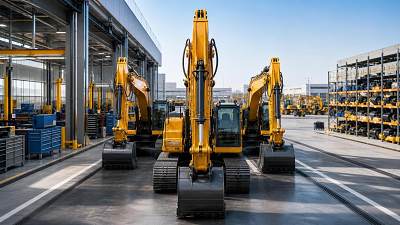
An EXCAVATOR for demolition should be selected from the top of the job downward. The first question is whether the machine can place the intended attachment at the required height, angle, and standoff distance while remaining within a stable working range. A compact building with thick reinforced slabs may demand less vertical reach than a narrow industrial structure with elevated steelwork, pipe racks, or suspended concrete sections. In practice, the machine that can safely hold the tool where the material actually breaks is usually the correct starting point.
Reach figures in brochures often describe a boom and arm geometry under standard conditions, sometimes with a bucket reference rather than a demolition attachment. That can be misleading. A pulverizer, crusher, or shear changes the machine’s working envelope because the tool has its own length, offset, jaw opening, and center of gravity. A long attachment may technically increase tip reach, yet still reduce usable control near the structure if the excavator loses stiffness or hydraulic responsiveness at full extension.
For that reason, reach should be separated into three practical measurements: vertical pin height, horizontal reach at the expected working elevation, and effective reach with the attachment opened or rotated into the breaking position. On demolition work, the last one often governs. A machine may touch the target wall, but if it cannot open the jaw, maintain tool pressure, and retract without dragging unstable debris toward the cab, that nominal reach has little value.
Working height is only useful when it remains stable under attachment load
Attachment weight is not a secondary specification. It changes the excavator’s center of mass, front-end moment, and sometimes the entire operating method. A boom built for earthmoving can feel acceptable with a bucket and still become unsuitable with a heavy concrete crusher mounted at full reach. The issue is rarely the static weight alone. Dynamic loading from tool closing force, swinging, and contact with partially attached material can amplify stress through the stick nose, boom foot, slew ring, and undercarriage.
Demolition attachments usually concentrate mass far ahead of the arm tip. A hydraulic shear for steel cutting, for example, can place more leverage on the front linkage than a simpler breaker of similar weight because of its geometry and body length. The excavator therefore needs enough counterweight, structural reinforcement, and hydraulic capacity to support both dead load and working load. If the specification sheet lists a maximum attachment weight, that figure should be treated as a starting limit rather than an automatic approval. The approved range may vary depending on boom configuration, front equipment length, and whether the machine uses a dedicated demolition package.
Where tool changes are expected, the coupler should also be considered as part of the suspended mass. Quick couplers, tilt couplers, rotation units, and adapter plates add weight and increase offset. That additional distance from the arm tip can reduce stability faster than the raw kilograms suggest. On high-reach work, even a moderate coupler weight can matter because the machine is already operating with a long front and limited reserve margin.
Attachment matching should include hydraulic behavior
Weight matching alone is incomplete. A demolition excavator may carry the tool structurally and still underperform because auxiliary hydraulics do not match the attachment’s flow and pressure requirements. Crushers and pulverizers often need smooth, consistent oil delivery for jaw speed and closing force. Breakers may require a different flow profile and back-pressure control. Rotators add another circuit requirement and can generate heat if the hydraulic system is not sized correctly.
If hydraulic oil cooling is marginal, attachment performance may degrade during continuous processing of reinforced concrete, especially in warm ambient conditions or enclosed urban sites with restricted airflow. Heat also affects seal life, hose durability, and valve response. The excavator should therefore be reviewed as a complete tool carrier: pump output, auxiliary line size, return flow arrangement, filtration, and accessibility of hose routing along the demolition boom all influence uptime.
Reach selection changes with demolition sequence
The correct reach is tied to the removal method. Top-down structural demolition normally requires the attachment to work from above the failure point while keeping the machine outside the collapse zone. In that situation, extra reach is not just convenience; it can create the stand-off distance needed to keep the undercarriage away from falling sections and dust concentration. By contrast, lower-rise processing of foundations, ground slabs, and stockpiled debris places more value on breakout force, tool cycle speed, and guarding than on extreme front-end length.
It is common to overvalue maximum pin height and undervalue mid-range control. A very long front may reduce accuracy when breaking parapets, edge beams, and column heads if the work is done in a narrow angular window. On congested jobsites, a machine with slightly less peak reach but stronger control at moderate extension can be the better choice. Demolition often involves partial cuts, pause-and-inspect sequences, and repositioning around unstable remnants. Those tasks favor predictable movement and clear operator feedback.
When the structure has varying elevations, separate the work into zones instead of seeking one machine to do every task at the edge of its capability. A dedicated high-reach excavator may handle upper sections, while a heavier standard-front machine processes lower levels and bulky debris. This can reduce front-end fatigue, improve tool productivity, and simplify transport because ultra-long demolition booms may need disassembly between sites.
Jobsite risk can invalidate an otherwise correct specification
A machine that fits the attachment and reach requirement on paper may still be wrong for the site. Demolition risk is shaped by more than structure height. Ground bearing capacity, proximity to live traffic, adjacent buildings, buried utilities, overhead lines, vibration sensitivity, dust suppression constraints, and emergency access routes all affect excavator selection.
Soft or disturbed ground deserves particular attention. Demolition jobs often create a changing surface made of crushed concrete, rebar fragments, voids, and wet fines. An undercarriage that is stable on compacted aggregate may behave differently on a slab edge over a basement void or on backfill disturbed by previous removal. Track width, shoe type, and the excavator’s overall operating weight matter because the machine may need to slew with a suspended attachment while standing on uneven debris. In these conditions, additional reach can increase overturning risk if the machine must work across a depression or toward unsupported edges.
Urban demolition introduces another layer of risk. Limited swing radius may be necessary near façades or property lines, but reduced-tail-swing machines are not automatically suitable for heavy high-reach work. Counterweight geometry, rear stability, and service access can become tradeoffs. A compact rear profile helps in tight sites, yet demolition still demands enough rear mass to balance the front equipment. The correct answer depends on whether the site is constrained by travel lanes, exclusion zones, or protected structures.
Guarding and visibility are part of machine selection
Cab protection, front window guarding, roof guarding, underbody shields, boom cylinder guards, belly plates, and travel motor protection should be evaluated as essential equipment wherever falling debris or sharp scrap is expected. These are not cosmetic options. Demolition exposes cylinders, hoses, lights, and glass to impact. Fine wire mesh, laminated glass, and heavy guarding may affect sightlines, so visibility should be checked together with protection level rather than treated as separate decisions.
High-reach work often benefits from cameras, boom-mounted viewing systems, and dust-resistant lighting. If the machine is expected to operate close to retaining walls, inside partially enclosed structures, or under pipe bridges, visibility to the attachment tip and surrounding hazards becomes as important as nominal reach. Poor sightlines slow the work and can encourage overreaching because the operator cannot clearly judge jaw position against cracks, reinforcement, or unsupported members.
Front-end design matters more than gross machine weight alone
Two excavators in the same operating-weight class may behave very differently in demolition because their front structures were designed for different duty cycles. Reinforced booms, thicker plate sections, extra guarding around pin bosses, heavy-duty stick ends, and revised cylinder mount areas indicate a machine intended to absorb repeated shock and torsional loading. Standard digging geometry may prioritize bucket crowd force and trenching efficiency, while demolition configurations often favor stability and attachment support across a broader arc.
Pay attention to pin diameters, bushing arrangements, hose protection, and grease point access. High dust, abrasive fines, and repeated shock can accelerate wear at the linkage. A design that is easy to inspect and maintain will usually perform better over time than one that hides wear points behind complicated guarding. In demolition, small clearances at the tool interface can become larger control problems because any looseness at the pins is magnified at the attachment tip.
Transport and assembly can change the practical machine choice
Selection often fails when site performance is considered in isolation. A demolition excavator with a long front, extra counterweight, and heavy guarding may require partial disassembly for road transport. That affects mobilization time, trailer configuration, crane support during assembly, and the space needed at the destination to install the boom set safely. On some projects, those constraints may favor a machine with a modular front arrangement or a lower overall height during transport, even if another model offers slightly better working reach.
Road access should be reviewed early. Tight city streets, bridge limits, soft site entrances, and restricted delivery hours can all influence what can realistically be brought to the work area. If the machine must cross temporary haul roads shared with heavy trucks, the interaction between transport equipment and excavator mobilization becomes part of the selection process. Demolition does not happen in a vacuum; machine access and support logistics shape actual productivity.
Do not ignore material type and break pattern
Concrete with dense reinforcement behaves differently from masonry infill, structural steel, timber roof framing, or composite industrial plant materials. A machine sized for brittle concrete breakup may struggle when the task shifts to cutting welded steel sections or handling long, entangled rebar. Material behavior changes the attachment requirement, and the attachment requirement may push the excavator into a different class.
For example, a processor intended to crush concrete and separate rebar imposes different demands than a steel shear that must hold and cut sections without excessive boom bounce. If the structure contains heavily reinforced transfer beams, post-tensioned elements, or thick foundation caps, the excavator needs enough stability and hydraulic authority to control the attachment through binding or uneven fracture. Jobs with mixed materials may justify prioritizing tool-change efficiency, hose routing protection, and balanced performance across multiple attachments rather than optimizing around a single peak specification.
Common evaluation mistakes
- Using maximum brochure reach as if it were safe working reach with a fully equipped demolition attachment.
- Counting attachment body weight but leaving out the coupler, rotation device, adapter bracket, and hose package.
- Assuming a higher operating weight automatically means a better demolition machine, without reviewing front reinforcement and hydraulic setup.
- Choosing the longest boom available for a site where collapse-zone distance, swing clearance, and transport access actually favor a shorter, stiffer configuration.
- Reviewing tool compatibility without checking oil cooling, return flow, and the effect of continuous duty on hydraulic temperature.
Maintenance exposure should influence specification
Demolition accelerates contamination. Dust, concrete fines, metal shards, and wrapped debris attack seals, radiators, coolers, and hose covers. A suitable excavator should allow routine cleaning and inspection without excessive panel removal. Reversible fans, wider cooler spacing, protected grease lines, and accessible auxiliary connections can reduce service interruptions. In abrasive environments, routed hoses should avoid snag points around the boom nose and stick underside, where broken concrete and steel edges are most likely to strike.
Undercarriage wear also deserves close attention. Tracking over rebar, crushed masonry, and sharp demolition spoil can shorten life of shoes, rollers, sprockets, and guards. If the job involves constant travel across demolition debris, an undercarriage designed for severe service may be more valuable than small gains in peak reach. This is especially true when the machine must reposition frequently inside a constrained footprint rather than stay in one prepared operating pad.
Where the specification should land
A sound selection usually emerges when three limits overlap: the attachment must be within the excavator’s approved suspended and working capacity, the required demolition reach must be available with real control at the tool tip, and the site must allow that machine to operate without forcing unstable positions. If any one of those conditions is weak, the machine may still function, but the operating margin becomes narrow.
In practical terms, the better excavator for demolition is often the one that looks slightly conservative in advertised reach yet has stronger front-end integrity, cleaner hydraulic matching, better guarding, and a more stable stance on the actual ground conditions. Demolition rewards reserve capacity. A machine working comfortably inside its envelope usually gives better control over debris, reinforcement, and sequencing than one selected at the limit of its chart.
When reach, attachment weight, and jobsite risk are reviewed together instead of as separate specification lines, the equipment choice becomes much clearer. That approach reduces the chance of selecting a machine that can touch the structure but cannot work it safely and consistently.
Trending News
- What paperwork is required for heavy equipment export shipments?
- How to reduce quality risks when sourcing dump trucks overseas
- How to assess a truck chassis supplier for trailer manufacturing
- Is the SHACMAN H3000 6×4 Cement Mixer suitable for large projects?
- How does a truck wing body improve loading and unloading efficiency?
Tag
Recommended News
 Buying GuideHow to assess a truck chassis supplier for trailer manufacturingTruck chassis supplier for trailer manufacturing: learn how to assess technical fit, quality control, engineering support, and delivery reliability for smarter sourcing.
 Buying GuideIs the SHACMAN H3000 6×4 Cement Mixer suitable for large projects?SHACMAN H3000 6×4 Cement Mixer: assess payload, cycle time, traction, and service support to see if it can keep large concrete projects moving efficiently.
 Buying GuideHow to evaluate heavy duty trucks for sale in Russia before buyingHeavy duty trucks for sale in Russia: learn how to compare specifications, winter readiness, service support, supplier reliability, and total ownership costs before buying.
 Buying GuideWhat to verify before choosing a logging truck producerChoose a logging truck producer with confidence: verify chassis strength, load security, compliance, service support, and delivery control for demanding forestry routes.
 Buying GuideHow to choose a truck excavator for confined construction sitesTruck excavator selection for confined sites: explore access, reach, stability, attachments, and safety factors to choose a productive, space-efficient solution.
 Buying GuideHow to choose a bulk trailer for high-volume aggregate haulingBulk trailer selection guide for high-volume aggregate hauling—optimize payload, body type, safety, compliance, and total cost for reliable fleet performance.
 Buying GuideHow to compare truck tire rolling resistance for lower fleet fuel costsTruck tire rolling resistance explained: compare test data, tread design, maintenance, and total cost to cut fleet fuel costs with confidence.
 Buying GuideHow to evaluate quality control before choosing a truck trailer OEMTruck trailer OEM quality control: learn how to assess design validation, welding, material traceability, testing, compliance, and factory audits before you buy.
 Buying GuideHow to verify a dump truck supplier can meet your delivery deadlineDump truck supplier with quick delivery: learn how to verify stock, production capacity, quality control, and export logistics to keep your project on schedule.
 Buying GuideHow to size a bulldozer for mining operations by haul road gradeBULLDOZER for mining operations sizing guide: match haul road grade, traction, blade capacity, and stability to improve safety, productivity, and fuel efficiency.
 Buying GuideHow to evaluate a construction machinery manufacturer’s quality controlConstruction machinery manufacturer quality control: learn how to assess materials, welding, hydraulics, testing, and after-sales support before you buy.
 Buying GuideHow to verify an excavator manufacturer with CE certificationExcavator manufacturer with CE certification: learn how to verify documents, model traceability, and factory compliance to avoid sourcing risks and buy with confidence.
 Buying GuideHow to evaluate a crane truck exporter before placing a bulk orderCrane truck exporter evaluation made simple: learn how to verify compliance, production capacity, delivery reliability, and after-sales support before placing a bulk order.
 Buying GuideWhen does a refrigerator truck make more sense than insulated transportRefrigerator truck or insulated transport? Learn when a refrigerator truck delivers better temperature control, lower spoilage risk, and smarter cold chain ROI.
 Buying GuideWhen does a tractor truck make more sense than a rigid truck?Tractor truck or rigid truck? Learn when a tractor truck delivers better flexibility, payload efficiency, and long-haul value for growing freight operations.
 Buying GuideHow to choose the right BULLDOZER for land clearing on rough terrainBULLDOZER for land clearing on rough terrain: learn how to choose the right size, tracks, blade, and support setup to improve safety, productivity, and total project value.
 Buying GuideHow to evaluate a semi trailer distributor before placing a bulk orderSemi trailer distributor selection can make or break a bulk order. Learn how to assess technical support, quality control, documentation, delivery reliability, and after-sales service before you buy.
 Buying GuideHow to compare an excavator manufacturer for construction on uptime supportExcavator manufacturer for construction comparison starts with uptime support. Learn how to assess service response, parts availability, training, and escalation to reduce downtime risk.
 Buying GuideHow to choose the right hydraulic pump for truck-mounted equipmentHydraulic pump selection for truck-mounted equipment: learn how to match flow, pressure, PTO, and duty cycle to improve reliability, efficiency, and uptime.
 Buying GuideHow to choose a cab chassis truck for construction jobscab chassis truck for construction buyers: learn how to match payload, body plan, and site conditions to choose the right truck faster and avoid costly mistakes.
 Buying GuideHow to Choose the Right Truck Battery for Reliable Cold StartsTruck battery selection for reliable cold starts can reduce downtime and boost fleet uptime. Learn how to choose the right battery for winter performance.
 Buying GuideHow to Evaluate a Truck Parts Distributor for Lead Time and OEM TraceabilityTruck parts distributor evaluation starts with real stock visibility, lead time accuracy, and OEM traceability. Learn how to compare suppliers and avoid fitment, batch, and delivery risks.
 Buying GuideHow to Choose a Truck Gasket for Heat, Oil, and Pressure ResistanceTruck gasket selection made simple: learn how to choose the right truck gasket for heat, oil, and pressure resistance, avoid failure risks, and compare materials before sourcing.
 Buying GuideHow to Choose an Excavator for Demolition Based on Reach, Attachment Weight, and Jobsite RiskEXCAVATOR for demolition selection starts with real reach, attachment weight, and jobsite risk. Learn how to choose a safer, more productive machine for demanding demolition work.
 Buying GuideHow to Evaluate a Logging Truck Supplier for Payload, Durability, and SupportLogging truck supplier evaluation starts with payload, durability, and after-sales support. Learn what to compare to reduce downtime, control costs, and choose a truck built for real forestry work.